Guanrui Li
Guanrui Li
Research
Publications
News
Teaching
CV
ACP Lab
Light
Dark
Automatic
Conferences
Trajectory Planning Using Safe Ellipsoidal Corridors as Projections of Orthogonal Trust Regions
International Conference on Robotics and Automation (ICRA)
, 2026
Akshay Jaitly
,
Jon Arrizabalaga
,
Guanrui Li
Agility, Intelligence and Safety
PDF
Cite
Enhancing Human-Drone Spatial Awareness with a Mixed Reality Interface for Drone Assisted Interactive Navigation
International Conference on Unmanned Aircraft Systems (ICUAS)
, 2025
Sanket A. Salunkhe
,
Pranav Nedunghat
,
Luca Morando
,
Guanrui Li
,
Giuseppe Loianno
Multi-Robot Collaboration
Decentralized Nonlinear Model Predictive Control for Safe Collision Avoidance in Quadrotor Teams with Limited Detection Range
International Conference on Robotics and Automation (ICRA)
, 2025
Manohari Goarin
,
Guanrui Li
,
Alessandro Saviolo
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Multi-Robot Collaboration
PDF
Cite
Video
Optimal Trajectory Planning for Cooperative Manipulation with Multiple Quadrotors Using Control Barrier Functions
IEEE International Conference on Robotics and Automation (ICRA)
, 2025
Arpan Pallar
,
Guanrui Li
,
Mrunal Sarvaiya
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
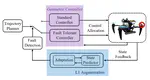
Experimental System Design of an Active Fault-Tolerant Quadrotor
International Conference on Unmanned Aircraft Systems (ICUAS)
, 2024
Jennifer Yeom
,
Roshan Balu T M B
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
PDF
Cite
Geometric Fault-Tolerant Control of Quadrotors in Case of Rotor Failures: An Attitude Based Comparative Study
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2023
Jennifer Yeom
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
PDF
Cite
Video
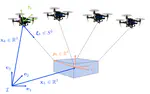
Nonlinear Model Predictive Control for Cooperative Transportation and Manipulation of Cable Suspended Payloads with Multiple Quadrotors
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2023
Guanrui Li
,
Giuseppe Loianno
Aerial Physical Intelligence
,
Multi-Robot Collaboration
PDF
Cite
Video
Learning Model Predictive Control for Quadrotors
IEEE International Conference on Robotics and Automation (ICRA)
, 2022,
Outstanding Deployed Systems Paper Award Finalist
Guanrui Li
,
Alex Tunchez
,
Giuseppe Loianno
Agility, Intelligence and Safety
PDF
Cite
Video
Vision-based Relative Detection and Tracking for Teams of Micro Aerial Vehicles
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2022
Rundong Ge
,
Moonyoung Lee
,
Vivek Radhakrishnan
,
Yang Zhou
,
Guanrui Li
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Multi-Robot Collaboration
PDF
Cite
Video
Aggressive Visual Perching with Quadrotors on Inclined Surfaces
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
, 2021
Jeffrey Mao
,
Guanrui Li
,
Stephen Nogar
,
Christopher Kroninger
,
Giuseppe Loianno
Agility, Intelligence and Safety
,
Aerial Physical Intelligence
PDF
Cite
Video
»
Cite
×