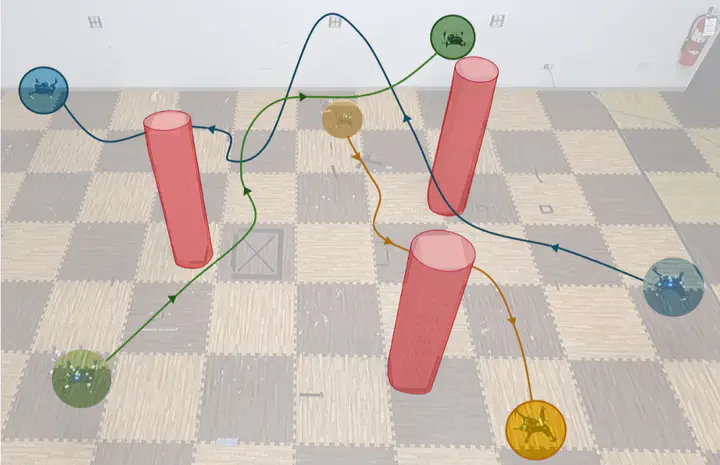
Decentralized Nonlinear Model Predictive Control for Safe Collision Avoidance in Quadrotor Teams with Limited Detection Range
Guanrui Li
Assistant Professor of Robotics Engineering
Assistant Professor of Robotics Engineering at WPI and director of the ACP Lab.