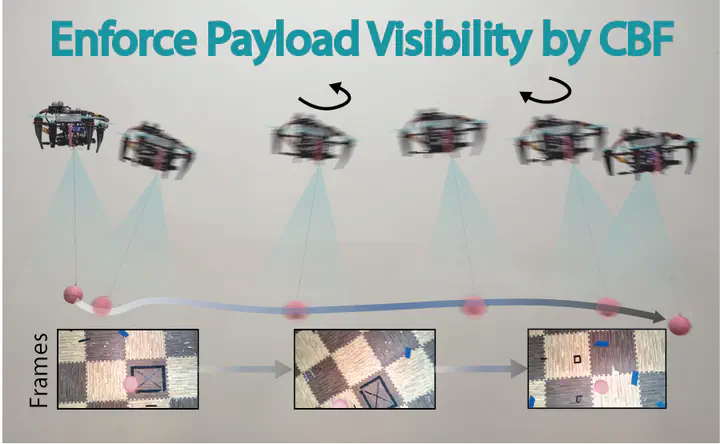
ES-HPC-MPC: Exponentially Stable Hybrid Perception Constrained MPC for Quadrotor with Suspended Payloads
Guanrui Li
Assistant Professor of Robotics Engineering
Assistant Professor of Robotics Engineering at WPI and director of the ACP Lab.
Assistant Professor of Robotics Engineering at WPI and director of the ACP Lab.