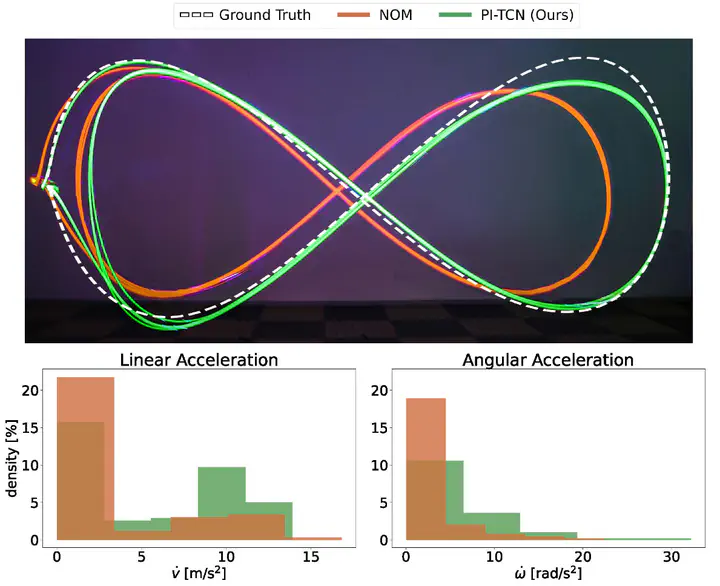
Physics-Inspired Temporal Learning of Quadrotor Dynamics for Accurate Model Predictive Trajectory Tracking
Guanrui Li
Assistant Professor of Robotics Engineering
Assistant Professor of Robotics Engineering at WPI and director of the ACP Lab.
Assistant Professor of Robotics Engineering at WPI and director of the ACP Lab.