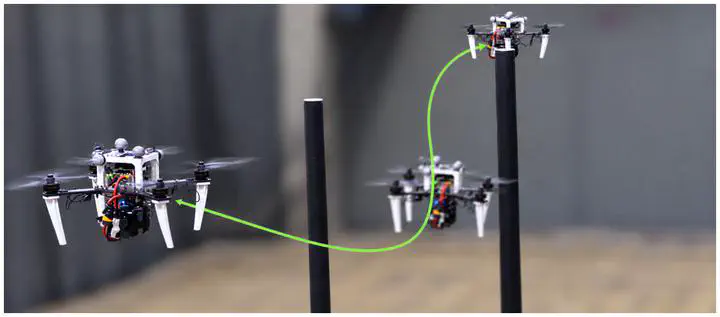
Safety-Critical Quadrotor Navigation Using Fourth-Order Control Barrier Functions with Full Nonlinear Quadrotor Dynamics
Guanrui Li
Assistant Professor of Robotics Engineering
Assistant Professor of Robotics Engineering at WPI and director of the ACP Lab.