Guanrui Li
Assistant Professor of Robotics Engineering
Worcester Polytechnic Institute
Aerial-robot Control and Perception (ACP) Lab
Dr. Guanrui Li is an Assistant Professor in the Department of Robotics Engineering at Worcester Polytechnic Institute, with an affiliated appointment in the Department of Mechanical and Materials Engineering. He is the principal investigator of the Aerial-robot Control and Perception (ACP) Lab. He serves as Associate Co-Chair of the IEEE RAS Technical Committee on Aerial Robotics and Unmanned Aerial Vehicles and as an Associate Editor for IEEE Robotics and Automation Letters (RA-L), IROS, and ICUAS.
He earned his Ph.D. at New York University, supervised by Prof. Giuseppe Loianno, now an Associate Professor of Electrical Engineering and Computer Sciences at the University of California, Berkeley. He received his master’s degree in Robotics from the GRASP Lab at the University of Pennsylvania, supervised by Prof. Mark Yim, and his bachelor’s degree in Theoretical and Applied Mechanics from Sun Yat-sen University, where he was recognized as an Honors Undergraduate.
Dr. Li’s research centers on multi-robot systems and aerial robotics, with applications in aerial transportation, manipulation, and human-robot collaboration. His work has earned several notable recognitions, including selection as an NSF CPS Rising Star in 2023, recognition as a finalist for the Outstanding Deployed Systems Paper Award at IEEE ICRA 2022, the 2022 Dante Youla Award for Graduate Research Excellence at NYU, and the 2024 NYU Outstanding Dissertation Award. He has published extensively in premier robotics conferences and journals such as ICRA, IROS, RA-L, and T-RO, and his work has been featured in media outlets including IEEE Spectrum and the Discovery Channel.
- Aerial Robotics
- Multi-Robot Systems
- Human-Robot Collaboration
- Model Predictive Control
PhD in Electrical and Computer Engineering, Robotics, 2024
New York University
Master in Robotics, 2018
University of Pennsylvania
BSc in Theoretical and Applied Mechanics, 2016
Sun Yat-sen University
Research
My research develops the planning, control, perception, and learning that let flying robots navigate the world, interact with it physically, and collaborate with other robots and people. At the ACP Lab we organize this work around three pillars:
- Aerial robot agility, intelligence and safety: fast planning and control, robust perception and estimation, learning-based navigation, and safety guarantees that let aerial robots fly aggressively and reliably in complex environments.
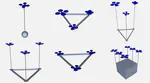
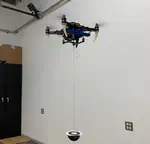
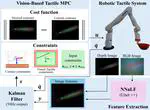
- Aerial physical intelligence: aerial robots that carry, manipulate, and make contact with the world, from cable-suspended payload transport and perching to tactile control and physical collaboration with people.
- Multi-robot collaboration: teams of aerial robots that cooperatively transport and manipulate objects, self-assemble into modular structures, avoid each other safely, and work alongside humans.
Our work is supported by the National Science Foundation and Amazon Robotics. The lab website has the people, student projects, and flight videos. If you are interested in joining the lab as a PhD student, postdoc, or WPI student, please read the Join Us page first.
Selected Publications
Recent News
Congratulations to Ethan Chandler, a Ph.D. student in the ACP Lab, on being selected as a 2026–2027 Amazon Robotics Fellowship recipient! Ethan’s research develops optimal control methods for underactuated systems such as quadrotors and legged robots. His new algebraic Riccati equation for spectrally discretized optimal control problems reduces the solve-time complexity from cubic to linear, enabling highly accurate agile motion, with quadrotor experiments reaching sub-centimeter accuracy at speeds above 10 m/s.
Contact
Prospective PhD students, postdocs, and WPI students: please read the ACP Lab’s Join Us page before emailing. It explains how to apply and what to include.
- gli7@wpi.edu
- UH 246, Unity Hall, 100 Institute Road, Worcester Polytechnic Institute, Worcester, MA 01609
- Join the ACP Lab